Buoyancy Analysis
This report outlines the design and testing of a buoyancy control system optimized for remote submarines. Key components include a powerful 12V Johnson electric motor achieving 16,000 RPM, lightweight aluminum cylinders, and a reliable Alexander Engel gear set. The system utilizes a Battery pack handling up to 2200mAh for sustained performance. Tests conducted include static motor strength and buoyancy assessments at various depths, aiming for neutral buoyancy and verified ascent/descent rates. Insights gained will enhance future developments in underwater robotics and remote marine vehicles.

Buoyancy Analysis
E N D
Presentation Transcript
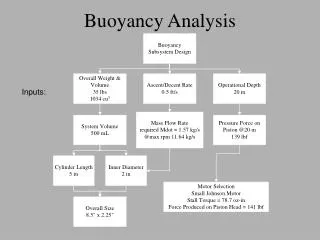
Buoyancy Analysis Inputs:
Buoyancy Mechanical Design • Johnson Electric Motor (12V) • High rpm (16,000 rpm@12V) • Lightweight (7.50 oz per motor) • Alexander Engel Gear Set • Proven for piston systems • Threaded Piston Rod • 6 mm • Piston Head • Aluminum • Machined in-house • Cylinder • Aluminum • Machined in-house • ID x OD x thickness: 2” x 2.25” x 0.125” • Batteries • 4 DuraTrax Receiver NiCd Flat Pack 6 Volt • 2200mAh (600mAh required per motor) • Length x Width x Height: 3-1/4“ x 1-3/4“ x 5/8" • Weight: 4.8 oz • Sealing • Precision Associates Inc. • Piston Head Seal • 75-1.840 1.84” ID x 0.075” C/S x 2.0” OD • End Cap Seal • 25-237 0.237” ID x 0.025” C/S x .287” OD
Buoyancy Electrical Design • Ballast Tank switch (BTS-II) • Proven system for remote submarines • Electronic (no servos) • Connects directly to Receiver • Stop-full micro switch • Stop-empty micro switch • Trim switch
Buoyancy Test Plan • Static Motor Strength Test (Feb 7th) • Verify System Produces force to operate at a depth of 20m • Horizontal Load Cell • Resolution: 1 lb • Range: 50 lb – 400 lb • Accuracy: +/- 1 lb • Expected Results: 141 lb force • Results: 11 lb force (Error due to incorrect moment arm calculation) • Buoyancy Subsystem Test (Never Achieved) • Verify descent and ascent rate • Antenna Marking w/ Stopwatch • Range: 0 – 6 ft • Resolution: 0.5 ft • Expected Results: 3.0 ft/sec • Minimum Requirement: 0.5 ft/sec • Overall System Test (Never Achieved) • Verify system remains neutrally buoyant at given depth • PX236 Pressure Transducer • Range: 0 – 60 psi • Bandwidth: 2 Hz • Resolution: 0.1 psi • Accuracy: +/- 1.5% • Expected Results: 3.0 ft/sec with neutral buoyancy (< 0.2 psi change) • Minimum Requirement: 0.5 ft/sec with 1 minute neutral buoyancy [1]